Yukari 3 ran a hand-built state machine to parse NMEA sentences coming from the GPS. It worked, but it was hard to maintain. I went looking for a tool that was a better solution. I was looking for something like a C++ template library that implements a state machine by abusing the template processor. What I found was Ragel.
This a nice, simple, clean program for generating finite state machines and weaving them into your programs. It does so in a way which I vastly prefer over Lex. It's main drawback is that since it is not a template library, it does require an external program to handle. Well, so do several other parts of my system. I use Perl without embarassment, so I will use Ragel similarly.
Ragel is structured very similarly to Yacc, in that it creates a program which executes user-chosen actions when a certain sentence form is encountered. However, it only handles part 1 languages, IE regular languages.
Ragel takes as input a source file written primarily in C/C++ (other languages are supported, but I don't use them) but which is marked with certain Ragel blocks. These blocks are used to define the machine and actions. The actions are written in the main language (C/C++ as I use it) and Ragel builds code which executes the state machine on an input stream and executes your actions as they come up.
It demonstrates a couple of interesting ideas, one of which is that you can just make up a new language and mix it into your existing source code.
Certain of the Ragel commands indicate where the state machine's tables should be written, where the state machine code should go, etc. Interfacing to the scanner is pretty simple.
A couple of examples below the fold:
Showing posts with label Gem of the Week. Show all posts
Showing posts with label Gem of the Week. Show all posts
Monday, August 3, 2015

Tuesday, July 14, 2015
#PlutoFlyby
As I type, there is a signal flashing across the solar system at the speed of light. It was transmitted by the New Horizons spacecraft, and while it is encoded in phase shift keying, circular polarization, ones and zeros, CCSDS packets, it carries a simple message. It's just a playback of engineering data. But, it carries the following important information, translated into English:

- I am still functioning properly and have survived flyby
- I have executed the observation sequence to this point, have made this many observations and recorded this much data
- I am going to shut up now and get back to recording data
Alternatively there is a lack of signal flashing across the solar system at the speed of dark, carrying the unfortunate message that New Horizons did not survive flyby, and this is the best picture of Pluto we will get for decades:

Thursday, March 21, 2013
Pinewood Derby and single-track Gray codes
It's time for the anuual Pinewood Derby at the cub scout pack I serve. Last year I was out of town during the Derby so I didn't participate. This year I am here, so I am making a car. I am not competing, of course, so I am free of certain constraints. Also, I never do any project like this in some ordinary way. As Emeril would say, I always try to kick it up a notch.
The design of the car is a pretty simple one, inspired by my first car back when I was in Cub Scouts. That year, we (me and my parents) thought aerodynamics was the most important thing, and so we designed the car accordingly. And finished dead last. Anyway, I still have fond memories of that car, like trying to microwave the car to dry the paint and charring the center of the block, nailing AA batteries to the back, putting my Battlestar Galactica 2" pilot action figure as a pilot. The general car design had a duckbill front and a turtle back. It was also solid red (what color do we hate?).
This time I have nicely polished the block to the point that it shines. I am going to leave the block completely unmarked.
But, that's not kicking it up a notch. Kicking it up a notch is installing a rocket engine in it. It's installing a camera. It's installing an electric motor. It's putting in a sensor for the car to time itself. I'm going to do the latter.
I have painted the back right wheel half white, including the tread, but with the hub very carefully masked off so as to not interfere with spinning. Over that wheel, I have installed two QRD1114 line-follower sensors. Each includes a near-infrared LED and a phototransistor. The sensor is close enough to visible light that things like white paint are still white and black is still black. The two sensors are placed roughly 90deg apart around the wheel, and about 1-2mm away from the tread. The idea is that the sensors use the half-white wheel as a single-track Gray code encoder wheel. Thinking about it this way: Suppose the car is rolling, the back sensor is well over the white part, but the front sensor just transitioned from black to white. Which way did the wheel turn? It must have been forward. If the back sensor were white but the front sensor changed from white to black, that means the wheel turned backward. Using this, we can construct a directional odometer, and measure the distance the car has moved. By timing the transitions, we can measure the speed of the car as well. By properly using both sensors, we can always know the direction of wheel spin and the orientation of the wheel to within a quarter turn.

So, the car will measure its own speed. We start the car with the wheel just past ticking over, so it has to turn one full time to count a rotation. The wheels are 15mm in radius, so we can measure the distance traveled. The microcontroller reading these sensors has a clock with microsecond precision and 4-microsecond resolution, so plenty enough to measure the exact time of each wheel rotation. Putting these together gives the car's speed, which it will print on an LCD display.
The gem this week is Gray code encoders, in particular single-track encoders. These have one track of code, and several sensors over that track at different angular positions. You need one sensor for every bit of code (two in my case for a 2-bit, 4 position code), but with careful design of the code track, you can use the same track for different bits, by shifting the sensors around the wheel a bit. This can be continued until you use the same track for all the sensors.
The design of the car is a pretty simple one, inspired by my first car back when I was in Cub Scouts. That year, we (me and my parents) thought aerodynamics was the most important thing, and so we designed the car accordingly. And finished dead last. Anyway, I still have fond memories of that car, like trying to microwave the car to dry the paint and charring the center of the block, nailing AA batteries to the back, putting my Battlestar Galactica 2" pilot action figure as a pilot. The general car design had a duckbill front and a turtle back. It was also solid red (what color do we hate?).
This time I have nicely polished the block to the point that it shines. I am going to leave the block completely unmarked.
But, that's not kicking it up a notch. Kicking it up a notch is installing a rocket engine in it. It's installing a camera. It's installing an electric motor. It's putting in a sensor for the car to time itself. I'm going to do the latter.
I have painted the back right wheel half white, including the tread, but with the hub very carefully masked off so as to not interfere with spinning. Over that wheel, I have installed two QRD1114 line-follower sensors. Each includes a near-infrared LED and a phototransistor. The sensor is close enough to visible light that things like white paint are still white and black is still black. The two sensors are placed roughly 90deg apart around the wheel, and about 1-2mm away from the tread. The idea is that the sensors use the half-white wheel as a single-track Gray code encoder wheel. Thinking about it this way: Suppose the car is rolling, the back sensor is well over the white part, but the front sensor just transitioned from black to white. Which way did the wheel turn? It must have been forward. If the back sensor were white but the front sensor changed from white to black, that means the wheel turned backward. Using this, we can construct a directional odometer, and measure the distance the car has moved. By timing the transitions, we can measure the speed of the car as well. By properly using both sensors, we can always know the direction of wheel spin and the orientation of the wheel to within a quarter turn.
 |
| I was disappointed to see that Bele and Lokai wear gray gloves. Bele doesn't wear gloves here! |

So, the car will measure its own speed. We start the car with the wheel just past ticking over, so it has to turn one full time to count a rotation. The wheels are 15mm in radius, so we can measure the distance traveled. The microcontroller reading these sensors has a clock with microsecond precision and 4-microsecond resolution, so plenty enough to measure the exact time of each wheel rotation. Putting these together gives the car's speed, which it will print on an LCD display.
The gem this week is Gray code encoders, in particular single-track encoders. These have one track of code, and several sensors over that track at different angular positions. You need one sensor for every bit of code (two in my case for a 2-bit, 4 position code), but with careful design of the code track, you can use the same track for different bits, by shifting the sensors around the wheel a bit. This can be continued until you use the same track for all the sensors.
Friday, February 8, 2013
Gem of the Week - On-Demand Printing
The Big One, by Stuart Slade. World War II went very differently, with England basically surrendering after Dunkirk, immediately drawing the USA into the war. With the Western front secure, Germany was able to focus on the Russian front. They captured Moscow (and killed Stalin, good riddance) but were stopped short of the Urals by the combined Russian and American armies, where they stalemated for five years.
One day in 1947, that changed. On that day, over a thousand planes were launched from bases all along the East Coast of the United states, carrying over 200 Mark III atomic bombs. These were upgraded from the Mk3 used in our timeline, with a typical yield of 35kT instead of the 20kT of Trinity and Fat Man. The main bombers were B-36s, with four bombs each. Each bomber had two escorts, also B-36s.
Interestingly, once the bombers were over Germany, they turned on Salvage Fuses, which would set the bombs off once they reached 2000ft, even if still in the plane. So even shooting down a bomber won't save you. In fact, the second blast was due to this very effect. That's just mean...
One hundred fifteen bombs are accounted for in the book, including twelve for Berlin, eight for Munich, and twenty-five between Dortmund and Bonn. Two were in the Frankfurt area, one in Koblenz, one in Heidelberg, but none in Rothenberg. Estimated casualties are twenty million immediate fatalities and probably that many again from radiation, lingering injuries, illness, and the collapse of civilization and famine caused thereby. The population of Germany was about 60 million in 1945, real world timeline.
It's an interesting story, but it has some holes in it, like how in the world did General Groves keep Manhattan secret for two additional years while they built up the stockpile? I got the book largely to see the answer to that question, but I didn't find it. Also, I am surprised they didn't base in Russia. However looking at the map, it is almost as far from the Front to Germany as it is all the way from America.
But none of that is the Gem. I found out about the Big One on the TV Tropes Wiki in late January, and after failing to find the story in free form on the net, I decided to shell out and buy the book on Friday, 1 Feb 2013. The last page of the book is marked:
One day in 1947, that changed. On that day, over a thousand planes were launched from bases all along the East Coast of the United states, carrying over 200 Mark III atomic bombs. These were upgraded from the Mk3 used in our timeline, with a typical yield of 35kT instead of the 20kT of Trinity and Fat Man. The main bombers were B-36s, with four bombs each. Each bomber had two escorts, also B-36s.
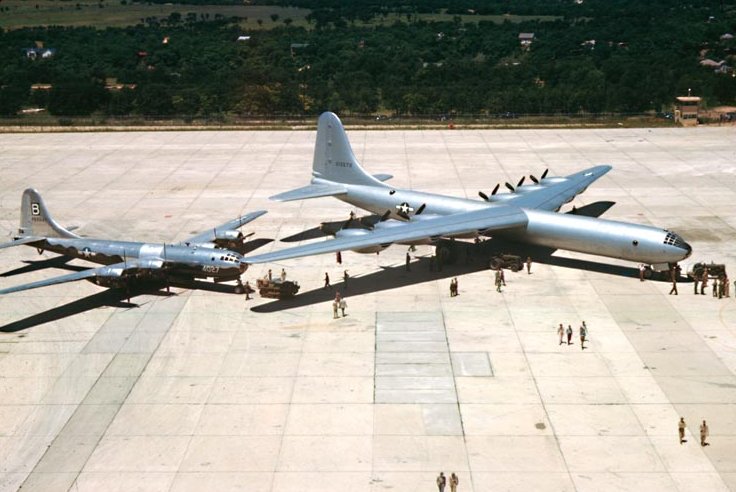 |
| That smaller plane to the left is a B-29. To put it mildly, the B-36 is a large aircraft. |
Interestingly, once the bombers were over Germany, they turned on Salvage Fuses, which would set the bombs off once they reached 2000ft, even if still in the plane. So even shooting down a bomber won't save you. In fact, the second blast was due to this very effect. That's just mean...
One hundred fifteen bombs are accounted for in the book, including twelve for Berlin, eight for Munich, and twenty-five between Dortmund and Bonn. Two were in the Frankfurt area, one in Koblenz, one in Heidelberg, but none in Rothenberg. Estimated casualties are twenty million immediate fatalities and probably that many again from radiation, lingering injuries, illness, and the collapse of civilization and famine caused thereby. The population of Germany was about 60 million in 1945, real world timeline.
It's an interesting story, but it has some holes in it, like how in the world did General Groves keep Manhattan secret for two additional years while they built up the stockpile? I got the book largely to see the answer to that question, but I didn't find it. Also, I am surprised they didn't base in Russia. However looking at the map, it is almost as far from the Front to Germany as it is all the way from America.
But none of that is the Gem. I found out about the Big One on the TV Tropes Wiki in late January, and after failing to find the story in free form on the net, I decided to shell out and buy the book on Friday, 1 Feb 2013. The last page of the book is marked:
Made in the USA
Lexington, KY
02 February 2013
The book was made after I ordered it. It seems that it was literally made for me.
Saturday, February 2, 2013
Gem of the Week - EEPROM I2C Memory
Of course I am designing a Rocketometer around the Propeller. How could it be otherwise?
In doing so, I have to get my own parts. The Sparkfun breakout is an interesting jumping-off point, but they don't even use bypass caps, so I added a set of those. Also one thing which concerns me about this whole endeavor is that all the memory is limited. Each cog gets 2kiB, for a total of 16kiB, but the images for each cog must be stored in main memory, which has 32kiB of RAM and 32kiB of ROM. There is no way that I am going to be able to get the program source code embedded with that little amount of memory.
This brings us back to the EEPROM on the breakout board. The bootloader burned into the Propeller knows how to bit-bang an I2C interface and read a memory on the bus. It treats the memory as a 32kiB byte-addressable memory with auto-increment, so it can set an address once, then read and read and read and fill main RAM. The Propeller documents say to use a 24LC256 or similar, so I got to looking at Digikey to see if they had that chip, and perhaps more interestingly, if there was a bigger chip which would still work. It turns out that the design of the EEPROM is the gem of the week.
First, the hardware. The 24LC256 is a 256kib memory organized as a 32ki x 8 (byte-addressable) memory. It is in a kind of large package, a whopping 5mm wide, with 8 pins. This is a lot for a device which is I2C and could in principle work with only 4 pins. But here is the cleverness. The device has three address pins, allowing the 7-bit I2C address to be anything in the range 0x50-0x57. So, you could just stack up to 8 devices on the bus, with only the address pins different, and get 32x8=256kiB of memory, at the cost of using 8 devices.
The 32kiB space is addressable with 15 bits, but the I2C protocol is byte-oriented, so you have to send 16 bits, of which only A0-A14 are considered, and A15 is ignored.
These facts work together to allow the address space to be easily extended. First, a 64kiB part is doable just by considering A15 in the address. Next, a device can internally answer more than one address, for instance by ignoring the A0 hardware pin and answering both 0x50 and 0x51. This of course means that you have to readdress the device when you cross from the address space covered by 0x50 and the one covered by 0x51. You would have to do that anyway if there were multiple real devices.
This all adds up to the STMicro M24M02, which appears to be compatible with the 24LC256, in that if you talk to an 'M02 like a '256, it will answer like a '256. So, you can use the larger device and the bootloader should happily just work. However, it is a 2Mib memory organized as 256ki x 8 (256kiB), eight times as much memory as the reference design, and approaching comparability with the LPC2148 and its 512kiB of Flash. Then when your application takes over, you can use your own bit-bang to access the full chip.
The 'M02 still has one address pin, so in principle you could make a 512kiB memory in 1 chip without changing anything. Going beyond this will break the nice de-facto protocol going on here.
Friday, January 25, 2013
Gem of the Week - the Parallax Propeller
I write this before ever using one, so consider this a review of the concept rather than the implementation. The Parallax Propeller is a microcontroller with a couple of interesting features, and perhaps more interestingly, a couple of intentionally missing features.
First off, it has no peripherals other than 32 GPIO pins.
Secondly, it has no such concept as interrupt.
Thirdly, it has eight independent processors, called "cogs", each with its own memory. Each one can run on its own resources without interfering with any other processor. Each cog is a 32-bit processor, and gets access to 2kiB of ram, shared between code and data.
Fourth, it has a set of resources that all processors can access, called a "hub". This basically consists of more memory and a round-robin memory controller which each cog can access in turn. The hub has 32kiB of ROM with the bootloader, Spin interpreter, and a couple of tables, and 32kiB of RAM.
The missing features are what make the controller interesting. Want an I2C? Write a program for a cog which can bit-bang it. Same for SPI, UART serial, etc. Presumably it could bit-bang low-speed USB, but high-speed would be difficult due to limited processor speed.
Further -- want an interrupt? Too bad. Instead, assign a cog to sleep-wait for the appropriate signal.
Programming such a beast is clearly a different problem than programming an ARM of any flavor. ARMs are all about peripherals, registers, interrupts, etc. Propeller is about bit-banging. Effectively you can use a cog as a soft-peripheral to do basically any digital process.
As I mentioned above, the processor comes with a Spin interpreter. Spin is a custom language for programming Propeller, which gets compiled into byte code and interpreted with the Spin virtual machine. Of course you give up performance, but they used an interpreter in the Apollo Guidance Computer. There, it was for memory saving - a single interpretive instruction could take the place of many instructions in AGC machine language. They gave up time to gain space. Spin could have similar benefits, but it seems like the main purpose is providing a language which natively handles the very different concepts needed to handle a processor as weird as the Propeller.
A Propeller program then consists of a bunch of Spin and machine language routines, all stored in hub RAM and copied from some external source whenever the chip resets. Aside from self-modification or using a cog to bit-bang a memory bus, this is all the space you get. This is a rather tight restriction, in fact less memory than in the AGC. But, they fit a full-blown Kalman filter into that.
Of course I have already designed it into a Rocketometer. It's what I do. One of the great things about the GPIO and bit-banging style of the Propeller is that I can put the SPI bus on the pins which are closest to their targets outside the chip. This makes routing the board MUCH easier.
So I will say for now that Propeller shows a lot of promise. The design is a gem. We will see about the implementation.
Wednesday, January 2, 2013
Gem of the Week: The Free Market
Or: They had Opportunity, in their very Community
Dear Princess Celestia,
Recently there was a severe shortage of apple cider here in Ponyville, which we had the opportunity to remedy, but because of short-sidedness on the part of some of your subjects and your apparent policy to grant monopolies in too many areas of the market, we chased that opportunity out of town.
In Ponyville, the cider franchise is granted to the Apple family of Sweet Apple Acres. Their orchard is a relatively small business and is incapable of supplying the demand. Cider prices are also too low, due to your policies of price control on cider, so the Apples are losing out as well. As a consequence, hundreds of ponies, a good fraction of the citizens of Ponyville, are deprived of cider, and those that do get it are forced to pay for cider with their time rather than with bits, by camping out at the gate. The time that they are granted, all those moments that will never exist again, they were forced to spend waiting rather than doing what they wanted.
If it seems cruel and heartless to give priority to ponies just because they have more bits, consider that your current policies are cruel and heartless as well to those who don't get any cider because they don't have as much time to waste in line. Even those ponies who do choose to spend those moments that will never exist again, pay for cider with both bits and time. Those customers spent that time to no benefit to anyone -- not themselves, and not the Apple family. If time were bits, it is as if those bits of time were carefully collected, from both the ponies who got cider and those that didn't, and dropped into Tartarus, never to be recovered, and never doing any pony any good. Even worse, those ponies who don't end up getting any cider pay time for cider they don't get.
A pair of entrepreneur ponies, the Flim Flam brothers, tried to remedy this, but because of the cider monopoly, they were unable to simply purchase the Apple family apples as a raw material and make the additional cider the market demands. The new business attempted to enter into collusion with the established players, but were unable to negotiate a cartel, which may have been even worse than the monopoly. By denying market competition, they were forced to compete in other ways, in this case a single-elimination to-the-out-of-business contest of pure quantity of production, rather than the ability to satisfy customer demand. In this competition, the Apple family was forced to work far beyond its sustainable capacity to near-exhaustion, and the Flim Flam brothers were forced to compromise their quality control, leading to inferior cider and tired, thirsty ponies.
If your policy of granting monopoly franchises was rescinded, the Flim Flam brothers could have just purchased apples from the Apple family or other suppliers at the market rate, and the Apples and Flim Flam could have worked together without having to collude. If your policy of cider price control was rescinded, the Apples could have raised the price of their cider to the point that some ponies would have decided that the cider wasn't worth it. The same number of ponies would have been served, the Apples would have made more money, and those ponies at the back of the line but more willing to pay would have been able to get their cider. With another supplier, more ponies would have been able to be served, and even if Apple family cider is better than Flim Flam cider, something is better than nothing, and the market would have decided that Apple family cider was worth more, and would have paid more. Those unwilling to pay that much would have been able to pay less to get Flim Flam cider.
They call it capitalism, but it isn't really an -ism of any kind, just the invisible hoof at work, ponies working towards their own benifit but supplying the needs of all ponies.
Please consider changing your economic policies to allow freedom to your subjects to pursue the interests that seem best to them.
It's a new world with tons of cider, fresh squeezed and ready for drinking -- and also plenty of quills, sofas, anemometers, and maybe even things nopony has even thought of inventing yet, but would if they had time to think and invent instead of waiting in line for cider.
Your Fellow Citizen,
St. Kwan the Just
Monday, December 17, 2012
Gem(?) of the Week - the Minkowski metric
The Pythagorean theorem is one of those gems that I won't go into a lot of detail about, because it has been so well-covered before by others. Let's just say that it is a property of Euclidean space, in particular a consequence of the parallel postulate. I just mention it here because it is an example of a topic I am going to go over in great detail.
In 2D Euclidean space, we can figure out the distance of any point from any reference point by setting up a rectangular coordinate system with the reference point at the origin. If there were just two points we cared about, we could align the axes such that the X axis went through the other point, and then we could just read the distance off that axis. That's not really exploiting 2D space, so we will think about one reference point but lots of other points all over the plane. We can use the Pythagorean theorem to measure the distance from the origin to any point in the plane:
\[s^2=x^2+y^2\]
With this coordinate frame you can figure the distance between any two points, even if one is not at the origin, as follows:
\[s^2=(x_2-x_1)^2+(y_2-y_1)^2\]
By using the standard delta-notation from engineering, we can simplify this back to
\[s^2=\Delta x^2+\Delta y^2\]
Now what is true for 2D Euclidean space is also true for 3D. The Pythagorean formula works, you just have to extend it to cover the third dimension
\[s^2=\Delta x^2+\Delta y^2+\Delta z^2\]
Those crazy topologists have generalized the Pythagorean theorem to fit their weird bent rubber spaces. They say that any space, along with a function which takes two points as an argument and returns a number, is called a metric space, where that function is called the metric. The metric must obey certain axioms, most important of which is commutativity - the distance from point A to B is the same as the distance from B to A.
Some of the topologists twisted imaginings don't really admit such a thing as a straight line. They get around this by saying that if you look at any small enough piece of the space, it is close enough to flat that we can define a metric there. Some spaces are so bent as to not even permit this, but those spaces which do, are called manifolds. In a manifold we talk about points which are close together, and represent this in our metric with differential notation
\[ds^2=dx^2+dy^2+dz^2\]
Now on a manifold we can specify a series of points to draw a path through, find the distance between each, add them all up, and get the length of the path. In calculus-speak, we have every point on the path, and we integrate along the curve to get the distance. However for flat space, there is such a concept as a straight line, and it is the shortest distance between two points. If you take the delta-form above and integrate the differential form, you end up with the same thing. Because of this, we will just show things in differential form from now on.
The film Dimensions is all about extending the same concept to four- and higher- dimensional space. All the Euclidean axioms apply, and the fourth dimension is exactly like the other three, so it works into the metric the same way:
\[ds^2=dx^2+dy^2+dz^2+dw^2\]
One narrator talks about how 4D space is the prettiest, because it contains such things as the 24-cell. Also he says that it may be because real physical space is 4-dimensional also once you consider time. Blah blah Einstein aggressively ignore history blah blah blah. Spacetime is 4-dimensional, but here's the weird part.
Time is not the same as Space.
"Wait a minute" I hear you all saying - "Obviously time isn't the same thing as space. Duh." But, the whole reason we call time a dimension, and the same reason we don't call temperature a dimension, is that there are coordinate transformations that mix in time with space. I'm going off of memory, but this argument came to me through a little book called "Relativity and Common Sense". For instance, imagine a plane where every point is painted a different color. So, at each point we can measure three things, its x and y coordinate, and its color. If we rotate the coordinate frame, we mix together the x and y coordinates
\[\begin{eqnarray*}
x'=& &x \cos \theta&+&y\sin \theta \\
y'=&-&x \sin \theta&+&y\cos\theta\ \end{eqnarray*}\]
But, there is no rotation, no coordinate transformation which preserves our understanding of what coordinate transformation means, which can mix color and spatial coordinates. Color is not a dimension in this sense.
Well, Time is.
The transformation isn't just a rotation, but the Lorenz transformation from coordinates measured by one observer to coordinates measured by a relatively moving observer, depends on the relative speeds of the observers. And here's the weird thing - time is a dimension, but it is not just like the other three dimensions. In fact, the metric for the spacetime observing the Lorenz transformation is called the Minkowski metric, and it looks like this:
\[ds^2=dx^2+dy^2+dz^2-dt^2\]
See the minus in the time term? It says that the longer the time between two events, the shorter the distance, all other coordinates being equal.
It gets weirder than that. If the time difference is long enough, it drags the whole right side negative. The squared distance between two events is negative. The distance between two events is imaginary. In special relativity, we say that when \(ds\) is real and positive, it is called proper distance, and it is the distance between two events as seen by some observer who sees them happening at the same time. Further there is no way for a single observer to be present at both events without exceeding the speed limit in the space, which introduces its own problems. When \(ds\) is imaginary, the (real) coefficient is called proper time, and represents the time interval between two events as seen by an observer who sees them happening in the same place. A single observer can be present at both events without exceeding the speed limit.
See what I mean by weird? In Minkowski space, there is a speed limit imposed as part of the fundamental geometry of space. If we though of time as just a dimension like space, this is equivalent to saying that it is impossible for a line to exceed a certain slope (change in space dimension per unit change in time dimension). No such limit exists in Euclidean space. Spacetime is 4D, but not Euclidean. It is not the same 4D space discussed in Dimensions. The Pythagorean theorem is false, and therefore the parallel postulate is false. Minkowski space is the only flat (metric works across long distances) space I know of which is non-Euclidean.
Now the question is, are the regular polytopes the same in Minkowski space? Does it make sense to talk about polytopes? Is a polytope regular from one point of view but not from another? These and other questions can be answered by the Minkowski metric, but I don't know the answers. I was only recently even able to form the questions.
Let's finish this off with a visualization:
Sunday, October 7, 2012
Gem of the Week - Kepler's and Newton's laws and universal gravitation.
The discovery by Kepler of his laws of planetary motion is one of the more amazing bits of observational science, made more amazing by the lack of tools which he had to work with. But, that's not our gem of the week. Instead, we will see how Newton deduced that there is such a concept as universal gravitation, and proved that it worked. Actually we won't see how he did it, but we will see how it can be done with modern techniques such as vectors.
Monday, October 1, 2012
Gem of the Week - Euler's Identity
I am going to present a new feature to all my 0 readers - the "Gem of the Week". This is a reprise of a sometime feature on my old private blog, "Chemical of the Day". I am expanding the topic somewhat from chemicals to anything I find interesting. None of these are necessarily news, but they might be.
This week, it's Euler's Identity.
This week, it's Euler's Identity.
Subscribe to:
Posts (Atom)