Showing posts with label Reviews. Show all posts

Friday, February 8, 2013

Gem of the Week - On-Demand Printing

The Big One, by Stuart Slade. World War II went very differently, with England basically surrendering after Dunkirk, immediately drawing the USA into the war. With the Western front secure, Germany was able to focus on the Russian front. They captured Moscow (and killed Stalin, good riddance) but were stopped short of the Urals by the combined Russian and American armies, where they stalemated for five years.

One day in 1947, that changed. On that day, over a thousand planes were launched from bases all along the East Coast of the United states, carrying over 200 Mark III atomic bombs. These were upgraded from the Mk3 used in our timeline, with a typical yield of 35kT instead of the 20kT of Trinity and Fat Man. The main bombers were B-36s, with four bombs each. Each bomber had two escorts, also B-36s.
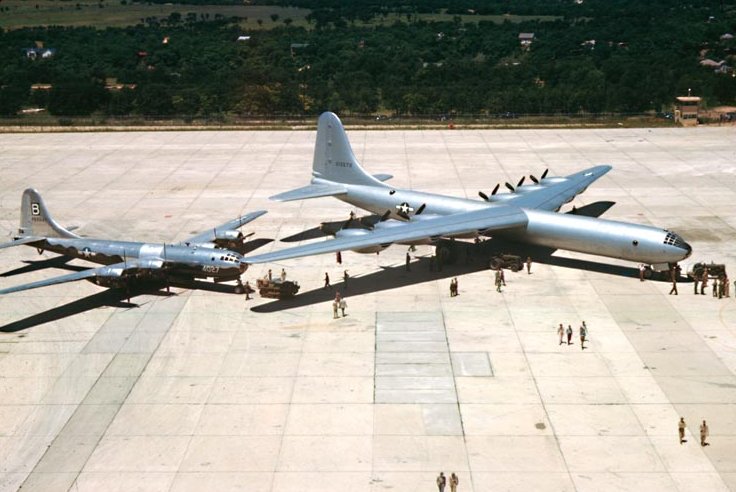
That smaller plane to the left is a B-29. To put it mildly, the B-36 is a large aircraft.


Interestingly, once the bombers were over Germany, they turned on Salvage Fuses, which would set the bombs off once they reached 2000ft, even if still in the plane. So even shooting down a bomber won't save you. In fact, the second blast was due to this very effect. That's just mean...

One hundred fifteen bombs are accounted for in the book, including twelve for Berlin, eight for Munich, and twenty-five between Dortmund and Bonn. Two were in the Frankfurt area, one in Koblenz, one in Heidelberg, but none in Rothenberg. Estimated casualties are twenty million immediate fatalities and probably that many again from radiation, lingering injuries, illness, and the collapse of civilization and famine caused thereby. The population of Germany was about 60 million in 1945, real world timeline.

It's an interesting story, but it has some holes in it, like how in the world did General Groves keep Manhattan secret for two additional years while they built up the stockpile? I got the book largely to see the answer to that question, but I didn't find it. Also, I am surprised they didn't base in Russia. However looking at the map, it is almost as far from the Front to Germany as it is all the way from America.

But none of that is the Gem. I found out about the Big One on the TV Tropes Wiki in late January, and after failing to find the story in free form on the net, I decided to shell out and buy the book on Friday, 1 Feb 2013. The last page of the book is marked:

Made in the USA
Lexington, KY
02 February 2013

The book was made after I ordered it. It seems that it was literally made for me.

Friday, September 28, 2012

A review of the ADXL345 and BMA180

First off, the ADXL345 is exactlty what it claims to be. It's my own fault for not reading the data sheet, or rather reading it but not comprehending the information in it.

So, my first experience with digital accelerometers was with the Bosch BMA180. The part had 14 bits of precision and 6 scale settings, from 1g to 16g. When you switched to the lower scales, you got more precision, as expected.

I finally got all 11 DoFs working on the 11DoF board. The first SPI part I broughs up was the ADXL345, so I learned about its SPI protocol that way. For one thing, those of you used to I2C, SPI is different! For instance, on both the ADXL345 and the gyro on the 11DoF, the L3G4200D, the register addresses are six bits. This is fine, since that is a big enough space. You send this address as the first word of any transfer in either direction from these devices. However, both devices use 8 bit words in the protocol. The other two bits control the direction of transfer for the other words, and whether the device is to expect more than one word -- that is, whether it should increment the register address pointer for the next words.

For instance, say you want to read all the measurement registers in the ADXL345. The register map says that this is registers 0x32 through 0x37. Since SPI is a full-duplex protocol, every time you send a byte, you receive a byte. So, send 0x32, ignore what you receive, then send six more bytes (doesn't matter what, I used 0) to read 6 bytes that you care about. Right? Almost, but not close enough. I did this first with the ID register, and it worked, sometimes. But, when I actually tried to read the data, I got back the same word six times. What gives? First, bit 7 of the address is read/#write. You have to set it to read the register, otherwise it interprets the MOSI data as data to be written to the registers. The data registers are read-only, so the part ignored me. Next, bit 6 is the multibyte flag. Set this bit if you are going to read/write multiple registers in one transaction (one continuous #cs assert). Doing this will cause the part to increment the address pointer each time it sends or receives 8 bytes. Since I set neither of these, my part became very confused, since I was telling it to write to a single read-only register six consecutive times.

tl;dr - Tell it you are using address 0xF2, then read 6 more times to get the 6 data registers.

This is an unnamed protocol layered on top of SPI, which by itself knows nothing of registers. It happens that the gyro uses the same protocol, so turning it on was a simple matter of verifying that the protocol was the same, and copypasting the code.

Now for the review. The ADXL345 has a programmable range, with choices ±2, 4, 8, and 16g. We will need 16g for the rocketometer. It has a readout precision of 13 bits, almost equal to the 14 bits the BMA180 gives. Now for the bad part. The readout precision is only 12 bits for 8g, 11 bits for 4g, and 10 bits for 2g. It is as if the part was always running at 16g, but reporting saturation if it was out of its current range.

I might as well use an analog part if I am only going to get 10 bits. I had always known this, but only realized the significance when I finally got it up and running, and only got about 250DN out of the part in the 1g field. So, the ADXL gets 2 of 5 stars, not recommended on the Chizumatic scale.

The BMA180 is what I used before, in flight. It has a programmable range, with choices ±1, 1.5, 2, 3, 4, 8, and 16g. It produces 14 bits of precision, and this 14 bits is constant across all ranges, so if you use the 1.0g range, you actually have zoomed in, and get better resolution than when you are at 16g. I can't speak to its accuracy, so it gets 4 of 5 stars, not recommended. Why not? The part was discontinued without a suggested replacement as of today, and is no longer available on Digikey. In fact, I am hoarding three of them still in their cut tape, purchased from Sparkfun today at great expense, not even on a breakout board. None of the other BMA accelerometers are as good, and none of the Analog Device accelerometers are as good either.

Friday, May 18, 2012

The LPC1768

It's sooooo close to being awesome. Cortex M3 with all the improvements (don't be scared by the word Harvard, the program-visible memory map is flat) and full pin compatibility with the 2368.

Almost.

This part has no SD/MMC port. Still, with SPI and DMA, maybe we don't need SD/MMC. The part is otherwise pin-compatible with the 2368, so the 2368 breakout board should work with a 1768 also.

I am going to get a 2368 talking to an SD card and sensor before I try messing around with the 1768.

Tuesday, March 27, 2012

LPC2368

I have a new favorite microcontroller: the LPC2368. It programs similar to the LPC2148 but is much more "digital" and much less "analog". It has four UARTs, three SPI ports, three I2C ports, something called I2S, two CAN ports (maybe I can talk to my car, or more like listen to it), two USBs, an ethernet port(!) and so on and so on. One big deal is a hardware SD/MMC port. My previous new love was the 2468, but that one has 208 pins and probably wouldn't fit on the Logomatic footprint, much less the stick IMUinator.

This guy has exactly 100 pins. The one big feature that the 2368 lacks is an external memory interface. That and a lot more GPIO pins. For two main reasons, the 2368 is more convenient to work with than the 2148:
  1. More pins means less overlap between functions. Several of the peripherals have dedicated pins (Ethernet, one I2C) so there is no problem with overlap. PWM and UART still overlap, but there are enough pins and two choices for each overlap that you can use all 6 PWMs and all of the UARTS.
  2. Fewer analog inputs, so those don't take as many pins.
The last is the only place where a 2148 is superior. The '2368 has six A/D inputs, but I use one of them for battery voltage, one for current, one for reference, and one is covered up by the USB Vbus input, leaving only two for use. You can sacrifice the voltage reference to get another channel, and I should think about doing the same for battery level and current sensing. It may also be possible to use another plain GPIO pin as Vbus, freeing up another A/D.

All the sensors I plan on using now and in the future are digital anyway, so to me, losing A/D is no big loss.

Also, all the peripherals except I2C have DMA, which I think means you can hand them a big block of data (or tell them to listen for a big block of data) and then the peripheral will take care of itself, while the core continues its programs. No more busy waits for the SD card.

I am working on a Loginator2368 which is increasingly less pin-compatible with the Loginator, but still roughly the same shape and size. Who knows if it can be made to fit on a Stick IMUinator?

Thursday, February 23, 2012

Desktop Microscopy and Charlieplexing

One of the things I used to have to do with all my custom boards is take them into the lab at work. There they have a really nice optical microscope. This one looks at things instead of through things, so it is appropriate for electronics (funny that, being in an electronics lab). It doesn't have an eyepiece as much as it has a facepiece. The end you look through has a screen (pure optical, no electronics or cameras involved) about 5 inches wide. It gives you a stereo view with a single objective lens, because each of your eyes is looking through a different optical path in the same set of lenses.


I have been searching for something like that and finally restricted myself to something I could actually afford, a USB digital microscope. I ended up getting this microscope.

Here's what I got it for - finding solder bridges

Really short depth of field. Do you want the top of the chip in focus...

...or its leads?
The subject of this particular set of pictures is Project Precision. For about five years now I have had a design in the back of my mind for a digital handed clock with an hour hand, minute hand, second hand and third hand (1 third = 1/60 second. Yes, really. Isaac Newton used thirds in the Principia.). I had a design using all 7400 series logic, a PIC and less 7400 logic, but finally came across the concept of charlieplexing. With 16 pins, I can control 240 LEDs. Only one at a time can be on, but I only need four on at a time, so I can strobe through those quickly enough.

The thing is USB powered with no battery. It uses an ATmega328 as the core and an FT232 for USB-UART conversion. This basically makes it an Arduino. It has a port for a GPS receiver as well, and a couple of multiplexers to connect the ATmega, FT232, and GPS in any combination.

What I'm most proud of is the layering. I needed 60 LEDs for each hand, and with four hands, I needed the front and back of two boards. I figured out a way to make these boards identical, so when I got three copies, I had enough, and didn't have to order three copies of two different boards.

Charlieplexing involves pairs of LEDs, pointing in opposite directions. If you set one end of this combo to VCC and the other to ground, one of the pair will light. If you do it the other way, the other will light. What I have done is put half of each pair on one board, and the other half on the other board. All the LEDs on the board with the logic will point outward, while the LEDs on the other board will point inward. It's almost fate that 16 signals can control 240 LEDs, the exact number needed for four hands. 16 was the exact number of signals left on the ATmega after I accounted for the UART, clock, multiplexer controllers, etc.

Now for the tedious task of picking and placing 240 diodes... Fortunately I only have to do them 60 at a time.

No, I will not make one for you, not for any price. Well maybe, but it would have to be a lot. Better is to make one yourself.

Tuesday, January 10, 2012

pcb.laen.org review

As you have seen in the pictures of the shiny purple boards below, I am ordering boards through Laen's service, http://pcb.laen.org/ . The boards are every bit as good as he claims. Shiny, purple, the gold touch is nice. Probably the best feature is that his fab house supports 6mil traces with 6mil spacing. When you really want to cram a board tight, and all of my boards tend to end up that way, 6mil traces can make the difference between finding a routing solution and not.

Laen is not a corporation, he is a person, and as such is subject to holiday breaks and other fatigues and weaknesses of being a person, but so are we all. Also, board delivery takes two hops. Even so, his boards still nominally make it back in about 1-2 weeks, which is quicker than Sparkfun's service, BatchPCB. Plus, the boards are purple, 6mil, and don't have any extraneous silkscreen. The price structures are different too, with the breakeven at about 5 square inches of board. Below this area, Laen is cheaper.

If you need a board, and aren't willing or able to make it yourself, consider Laen.

Tuesday, April 5, 2011

The ITG-3200

I have finally gotten some excellent calibration data out, and have determined one important fact. The ITG-3200 is a fine, fine sensor. Once the sensor is calibrated, with no noise filtering at all, it has an almost un-measurable drift over 17 minutes. It is good enough that you can just straight up integrate the body rates.

The ITG-3200 is available from Sparkfun, of course. Highly recommended for all your IMU needs.

The next task is to determine the relative orientation of the sensors to each other and to the frame of the Bridge board. This actually seems like it is quite doable. First, set up the turntable very carefully, using a circular bubble level to verify the spin axis is parallel to local gravity. I used about 10 sheets of paper to shim it.

Also, we are going to use the sides of the box on the turntable to make sure that the IMU box is always in the same orientation relative to the turntable.

Next, we do a calibration dance. The accelerometer measurement will be along local gravity, which we have made sure to make parallel to the IMU box frame. Any misalignment between local gravity and the accelerometer axes is attributable to misorientation of the sensor. When spinning, the vector body rotation will also be parallel to local gravity and the IMU frame, so we can identify its misorientation as well. Finally, I don't think that compass orientation matters that much, and I don't think that it is observable. Maybe by looking at the plane the measurement describes as the box is spun...


Thursday, March 31, 2011

New fun toy discovered!

Wolfram Alpha. It's like the Integrator, but solves more problems, including derivatives. It is well known that any elementary function has a derivative expressible as an elementary function (for an appropriate value of "elementary") and that the chain rule, product rule, sum rule, and power rule are sufficient to build an algorithm around to find any derivative. In fact, it was considered to be trivial, which is why Wolfram originally only published the Integrator.

Well, now it does derivatives. derivative of sqrt((x-a)^2+(y-b)^2) . It even shows its work, in the form that a person would do it on paper. So, no excuses now about derivatives. Just learn what one is, and let Alpha actually do them.